Motivation
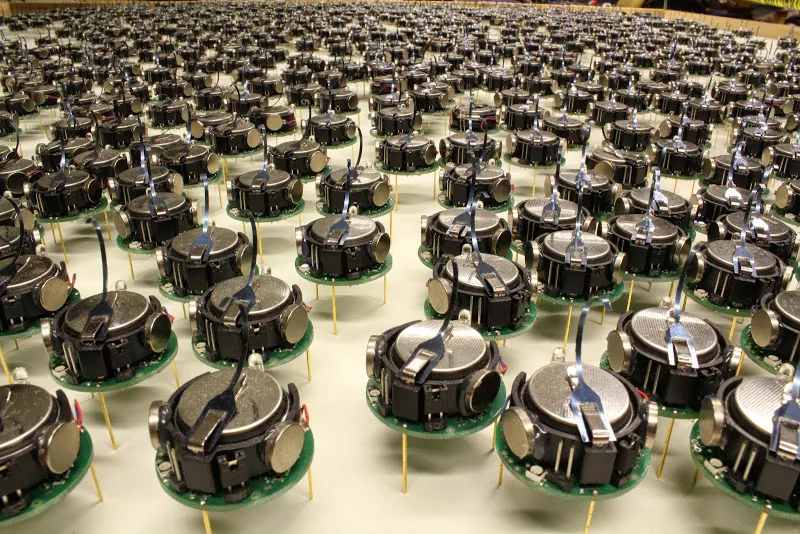
Swarm robotics is an approach to performing a task by using a large number of robots that coordinate to accomplish their common goal. Robotic swarms have been put forward a good alternative to single robots in a number of scenarios including tasks such as surveillance and maintenance of industrial plants.
In safety critical situations, it is necessary to verify that these swarm systems will behave as expected regardless of how many agents are present in the system. However, this cannot be achieved with traditional model checking techniques since it involves checking an unbounded number of systems. This project aims to develop novel model checking techniques that enable the verification of these unbounded multi-agent systems.
Objectives and current results
To enable the development of verification methods, the project aims at defining semantic models and formal specification languages for swarm systems.
A number of such semantics have been proposed, both for modelling synchronous systems (in which all the participants perform actions simultaneously) and asychronous systems (where participants may perform actions independently). Both non-deterministic and stochastic semantics have been considered, and formal specification languages have been explored ranging from those describing simple temporal properties to richer logics that can describe probabilistic, epistemic, or strategic properties.
These techniques have also been extended to address the verification of faulty systems (where the participants in the swarm may exhibit faults) and open systems (where participants of the swarm may leave or join at run-time).
More details on our current research can be found in the Software and Publications sections below.
Software
The following tools have been developed within the project:
- A number of extensions to MCMAS to enable the verification of non-probabilistic unbounded multi-agent systems. These can be found here.
- A number of variants of PSV (Probabilistic Swarm Verifier), which are built on top of PRISM and enable the verification of unbounded probabilistic multi-agent systems. These can be found here.
Team members
Principal investigator
- Prof. Alessio Lomuscio
Research associates
Collaborators
- Mr Edoardo Pirovano
- Mr Hashan Punchihewa
Funding
This research is supported by a Royal Academy of Engineering Chair in Emerging Technologies and an EPSRC-sponsored studentship.
It was previously also supported by an EPSRC fellowship on Trusted Autonomous Systems.